Systematically Exploring the Capabilities of GPT-6 Astra as Embodied Policies
arXiv Preprint, 2026
I am a full-time researcher and engineer at GALBOT, working on perceptive locomotion and navigation for legged robots.
Previously, I was a robotics algorithm intern at DEEP Robotics, working on locomotion control for quadruped robots; a research assistant intern at the Institute of Automation, Chinese Academy of Sciences, focusing on underwater robot perception and manipulation; and an autonomous driving algorithm intern at Mercedes-Benz.
Master of Robotics
Bachelor of Automation
High School
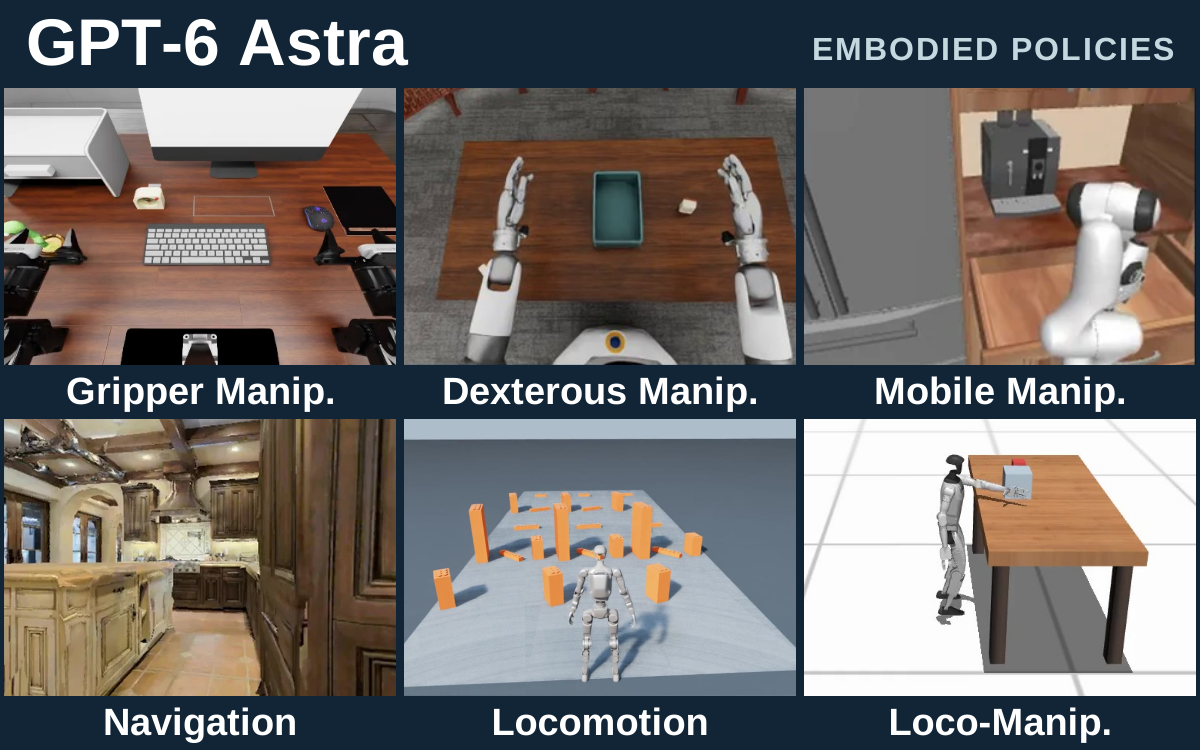
arXiv Preprint, 2026
Under Review
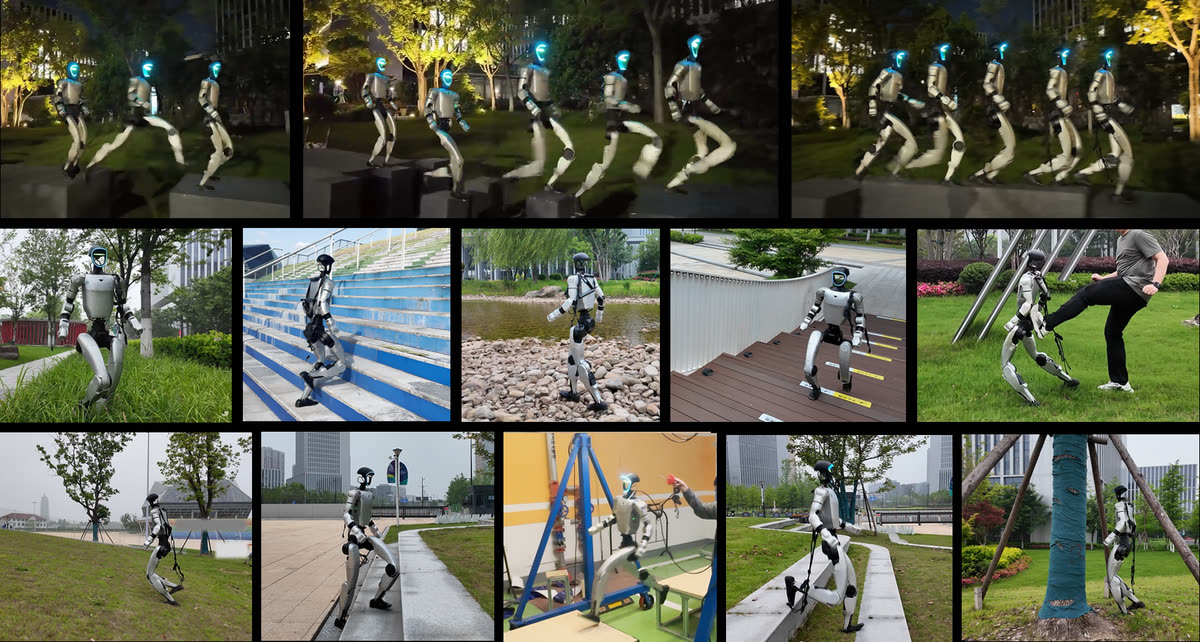
Under Review
IROS 2026
* Equal contribution.